Robotics
- Mobile robotics
- Industrial robots
- Drones
I'm Vishakh Duggal. I build autonomous systems that perceive, navigate, and act in the real world.
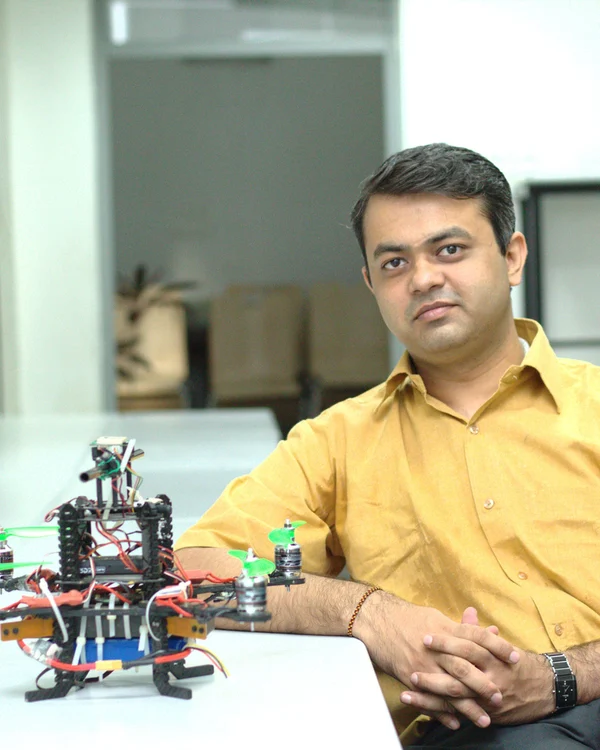
Robotics, research, and the engineering behind it.
A career across robotics, machine learning, embedded systems, and research.
Autonomous lawn-mowing AGV development on Modalix, with LightGlue and SuperPoint machine learning acceleration, RTAB-Map SLAM, Nav2 navigation, and ROS 2.
Project Manager
SLAM, 3D maps, and hardware/software feature prototypes for robotic vacuum cleaners.
Team Lead
Sr Robotics Engineer
Micro-drone firmware and ROS controllers using behaviour-tree modelling.
Sr Research Scientist for Autopilot development at IIT Kanpur, Aerospace Division
Autopilot development using the PX4 stack, NuttX RTOS, device drivers, and hardware integration.
Technical Specialist , Machine Learning and Robotics
Machine learning, cognitive robotics, vision-guided pick and place, and robotic satellite-docking validation.
Robotics Engineer: Robotics Software Development, RAPID, Linux and Device Drivers
Robot software architecture, software management, Linux migration, RAPID, and device drivers.
Senior System Software: Android OS development, Linux and Device Drivers Development
Android platform development, Linux, and device drivers.
Senior Software Engineer: Linux , Device Drivers, Bootloaders, Firmware development
Linux, device drivers, bootloaders, and firmware development.
Design Engineer: Verilog and FPGA development
Verilog and FPGA development.
A computer vision and machine learning proposal for industrial robot calibration, recognized among 40 teams.
A Microsoft HoloLens proposal for industrial robot manipulation and control, recognized among 60 teams.
Hosted at Hiroshima University and awarded by the Government of Japan.
Teaching and industry training alongside research and engineering.
Research in autonomous navigation, precision agriculture, learning, trajectory planning, and control.
Autonomous navigation of generic monocular quadcopter in the indoor environment requires sophisticated approaches for perception, planning and control. This paper presents a system which enables a miniature quadcopter with a frontal monocular camera to autonomously navigate and explore the unknown indoor environment. Initially, the system estimates dense depth map of the environment from a single video frame using our proposed novel supervised Hierarchical Structured Learning (hsl) technique, which yields both high accuracy levels and better generalization. The proposed hsl approach discretizes the overall depth range into multiple sets. It structures these sets hierarchically and recursively through partitioning the set of classes into two subsets with subsets representing apportioned depth range of the parent set, forming a binary tree. The binary classification method is applied to each internal node of binary tree separately using Support Vector Machine (svm). Whereas, the depth estimation of each pixel of the image starts from the root node in top-down approach, classifying repetitively till it reaches any of the leaf node representing its estimated depth. The generated depth map is provided as an input to Convolutional Neural Network (cnn), which generates flight planning commands.
Watch research demonstration ↗Recently, quadcopters with their advance sensors and imaging capabilities have become an imperative part of the precision agriculture. In this work, we have described a framework which performs plantation monitoring and yield estimation using the supervised learning approach, while autonomously navigating through an inter-row path of the plantation. The proposed navigation framework assists the quadcopter to follow a sequence of collision-free G P S way points and has been integrated with ROS (Robot Operating System). The trajectory planning and control module of the navigation framework employ convex programming techniques to generate minimum time trajectory between way-points and produces appropriate control inputs for the quadcopter. A new ‘pomegranate dataset’ comprising of plantation surveillance video and annotated frames capturing the varied stages of pomegranate growth along with the navigation framework are being delivered as a part of this work.
Watch research demonstration ↗Overtaking of a vehicle moving on structured roads is one of the most frequent driving behavior. In this work, we have described a Real Time Control System based framework for overtaking maneuver of autonomous vehicles. Proposed framework incorporates Intelligent Planning and Modular control modules. Intelligent Planning module of the framework enables the vehicle to intelligently select the most appropriate behavioral characteristics given the perceived op- erating environment. Subsequently, Modular control module reduces the search space of overtaking trajectories through an SVM based learning approach. These trajectories are then examined for possible future time collision using Velocity Obstacle. It employs non linear time scaling that provides for continuous trajectories in the space of linear and angular velocities to achieve continuous curvature overtaking maneu- vers respecting velocity and acceleration bounds. Further time scaling also can scale velocities to avoid collisions and can compute a time optimal trajectory for the learned behavior. The preliminary results show the appropriateness of our proposed framework in virtual urban environment.
Watch research demonstration ↗Autonomous navigation of generic monocular quadcopter in the natural environment requires sophisticated mechanism for perception, planning and control. In this work, we have described a framework which performs perception using monocular camera and generates minimum time collision free trajectory and control for any commercial quadcopter flying through cluttered unknown environment. The proposed framework first utilizes supervised learning approach to es- timate the dense depth map for video stream obtained from frontal monocular camera. This depth map is initially trans- formed into Ego Dynamic Space and subsequently, is used for computing locally traversable way-points utilizing binary integer programming methodology. Finally, trajectory planning and control module employs a convex programming technique to generate collision-free trajectory which follows these way- points and produces appropriate control inputs for the quad- copter. These control inputs are computed from the generated trajectory in each update. Hence, they are applicable to achieve closed-loop control similar to model predictive controller. We have demonstrated the applicability of our system in controlled indoors and in unstructured natural outdoors environment.
Watch research demonstration ↗The challenges in generating minimum time tra-jectory and control for generic quadrocopter flying through sophisticated and unknown environment are explored in this paper. The proposed method uses convex programming tech- nique to optimize polynomial splines, which are numerically stable for high-order including large number of segments and easily formulated for efficient computation. Moreover, exploiting the differential flatness of system, these polynomial trajectories encode the dynamics and constraints of the vehicle and decouple them from trajectory planning. The framework is fast enough to be performed in real time and results in solution which is close to time optimal. As control inputs are computed from the generated trajectory in each update, they are applicable to achieve closed-loop control similar to model predictive controller.
Watch research demonstration ↗From drone autopilots to Linux drivers. Project descriptions and individual contributions, together in one place.
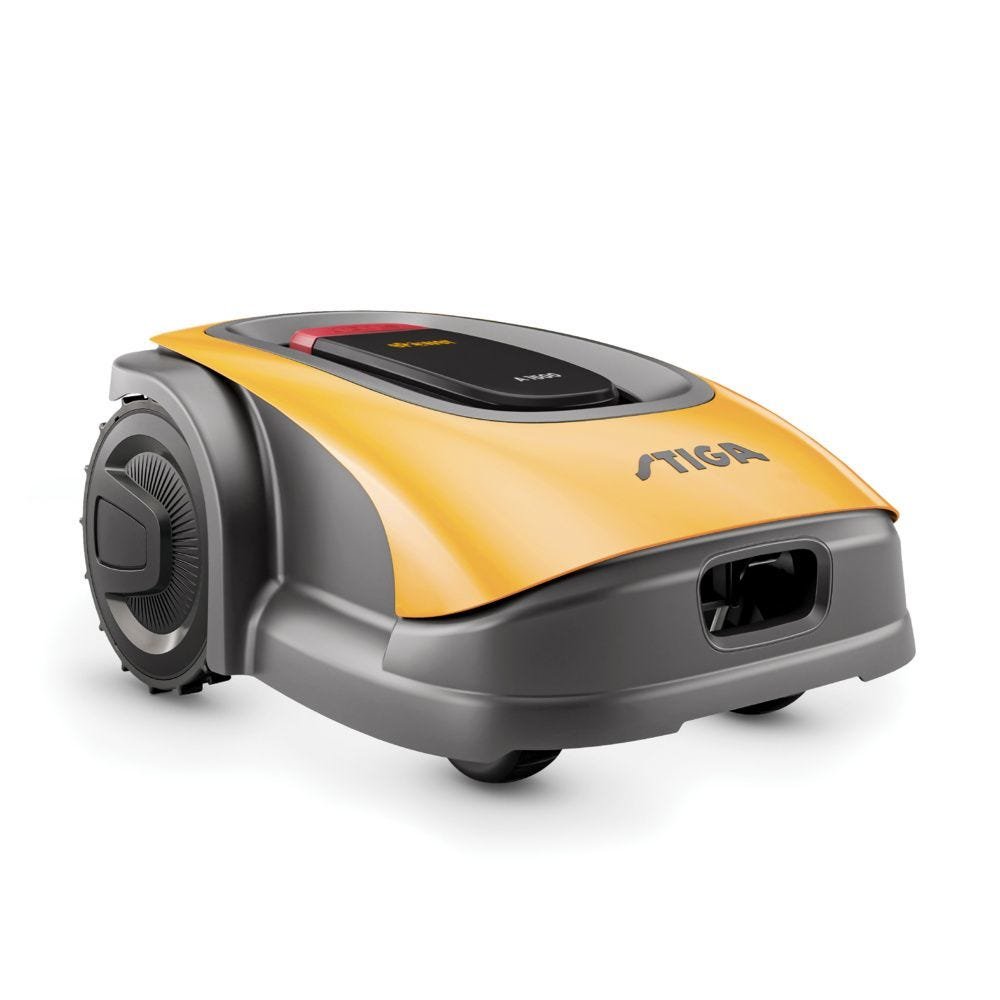 PROJECT / 01
SiMa.ai, 2026 - Present
Development of an autonomous lawn-mowing AGV using the SiMa.ai Modalix board.
Project technology stack and contributions:
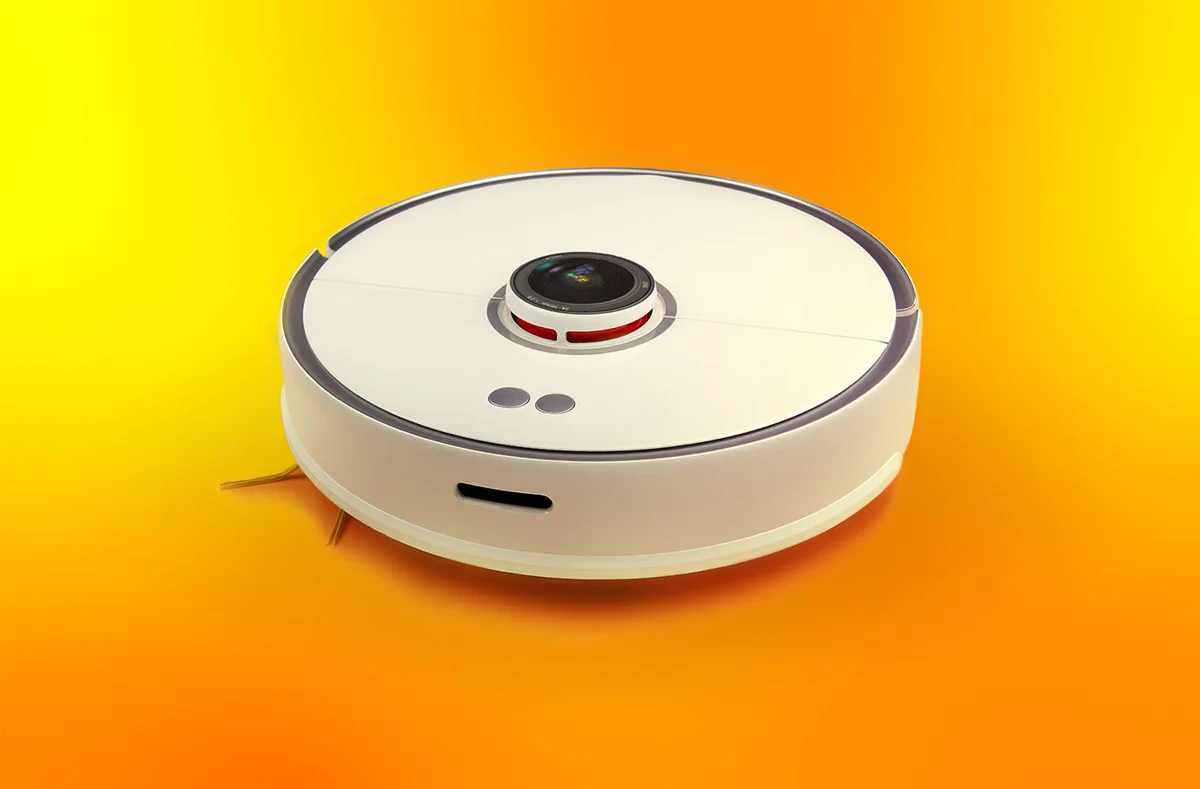 PROJECT / 02
LG, 2023 - 2025
Contribution to the Project:
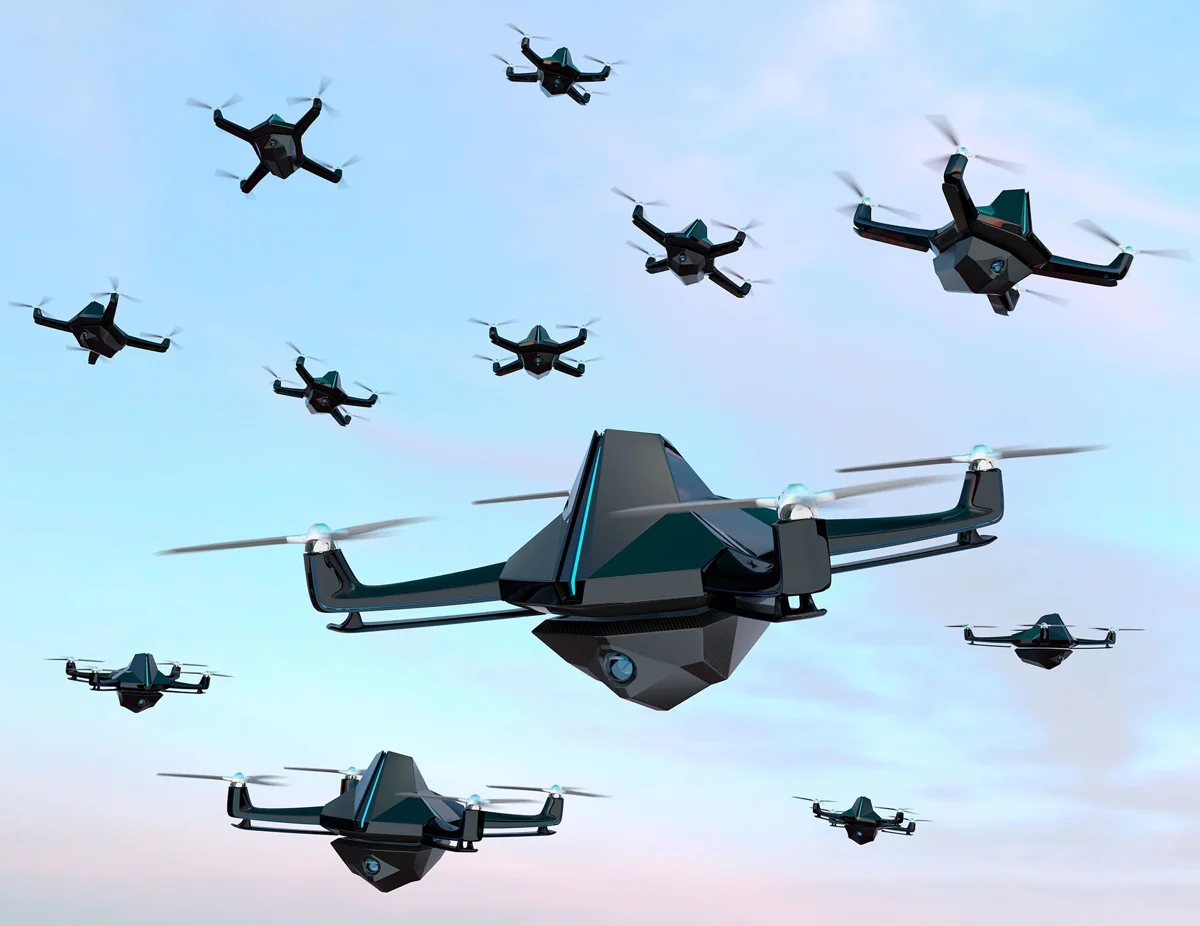 PROJECT / 03
Polybee Robotics ( Singapore Startup ) , 2021 - 2022
Contribution to the Project:
 PROJECT / 04
Indian Institute of Technology ( IIT ), Kanpur ( 2021 )
Development of Software for proprietary Autopilot software for Drones based on PX4 software stack
Contribution to the Project:
 PROJECT / 05
ABB Robotics (2018-2019)
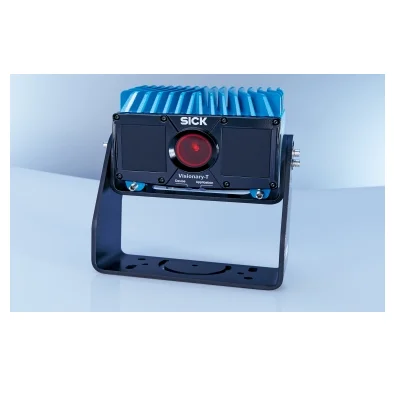
Pick and place is one of the upcoming domains that is pushing for automation. The vision-based solution was developed using 2D and 3D cameras for specific customer requirements.
Contribution to the Project:
 PROJECT / 06
ABB Robotics (2018-2019)
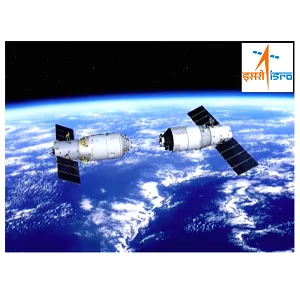
The satellite docking validation system is a project required by an esteem client which wanted to validate algorithms/sensors for satellite docking in space. This was achieved by two ABB IRB6700 robots mounted on 10 meter long conveyor belt. Both robots move towards each other, with motion directed by data received in real time from sensor on each of the robot end actuator and centralized algorithm for docking.
Contribution in the project:
 PROJECT / 07
ABB Robotics (2017-2018)
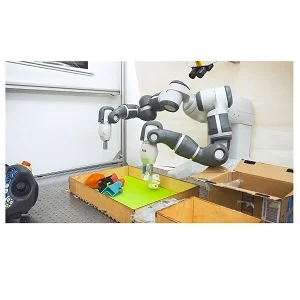
Cognitive intelligence for a robot with understanding of its environment was the focus of the Research project. User interacts with the robot using speech commands which based on the understanding of the environment (objects, actions etc) robot either performs or replies with question. This initial prototype was developed in 5 months with code using NLP, ML and Graph Libraries in Python.
Contribution in the projec:
 PROJECT / 08
ABB Robotics(2012-2013).
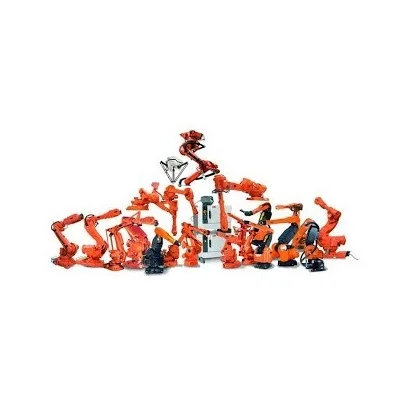
The Next Generation Robot Platform Software is one of the most important project which ABB Robotics is executing. This involves discarding legacy Robot Software Platform and creating new Software Platform from scratch which being more Open Source Compliant. It incorporates modular architecture, network security and allows 3rd Party software interfacing. The software is getting developed on Python and C/C++. The project also involves migrating from VxWorks to Linux OS.
My contribution included but not limited to:
 PROJECT / 09
Research(2014-2015).
This sponsored research project by Renault-Nissan focused on developing autonomous overtaking maneuver for vehicles. The project demonstrated the effectiveness of developed algorithm on TORCS and UC/Win simulators. The developed algorithm utilized non-linear time scaling and velocity cone based collision detection. Publication based on the work was accepted in IVS 2015.
Project Included:
 PROJECT / 10
Personal Project
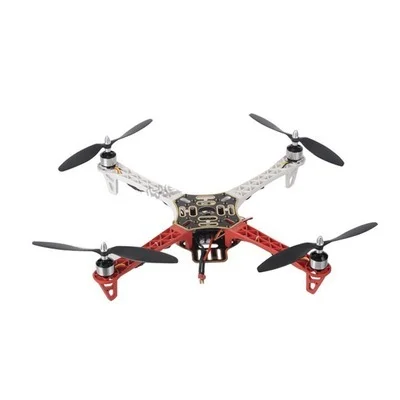
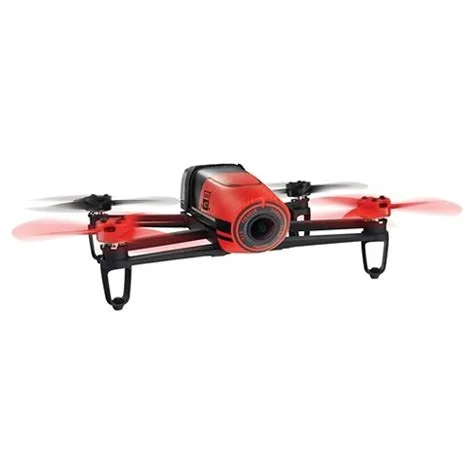
AR Drone 2.0 is a commercially available Quad-copter which can be controlled using library provided by Parrot or using AT commands and uses WIFI to transfer the commands to Quad-copter.
In this Experiment Asus Xtion Pro which is OpenNI compliant device is used with NITE middle ware to detect the motion and hand gestures of the user. Once detected ,these are converted to appropriate motion command for the quadcopter.
Project components :
 PROJECT / 11
S.T.Micro Electronics(2010-2011)
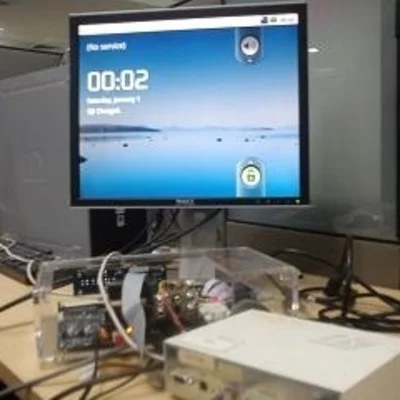
In September 2008, an Open Source software platform primarily for smart mobile phones called Android was launched by the Open Handset alliance led by Google. Android is a complete embedded software stack, comprising of a modified Linux based kernel, middleware, application framework and applications. To run Android on their platform, Original Equipment Manufacturers (OEMs) need to make hardware specific changes such as adding the Bootloader and writing kernel drivers for their devices and interfacing the Android stack with hardware platform drivers. STMicro took a strategic decision to move Android from Mobile platform to other Consumer Electric platforms such as SetTop Box and Digital TV.
Responsibilities in the project:
 PROJECT / 12
Research(2010-2011)
ST Micro decided to port Android to Set-top Box, where we faced a simple problem "How to navigate inside Android without touch screen ?"
As the Set-Top Box was connected to TV set and only interface available for interaction was a normal IR remote . Therefore it was decided to integrate IR set-box remote with Android subsystem allowing seamless experience to the user.
Project milestones :
 PROJECT / 13
N.X.P. Semiconductors(2008-2009)
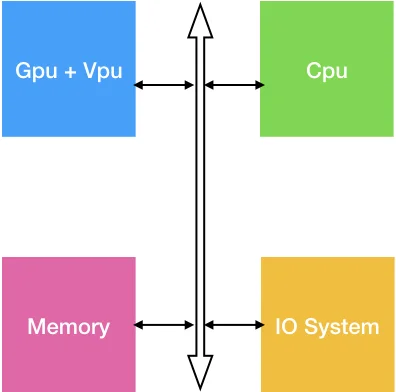
System upgrade is a tedious task which requires from formatting flash partitions, downloading new image to burning new image into the new system. Mostly in embedded world JTAG is prominently used for accessing ,configuring and formatting the system flash.
Due to high cost of JTAG, it was decided to replace the system upgrader using JTAG with serial port (UART) and USB based updating process.
Project Responsibilities:
 PROJECT / 14
Research(2008-2009)
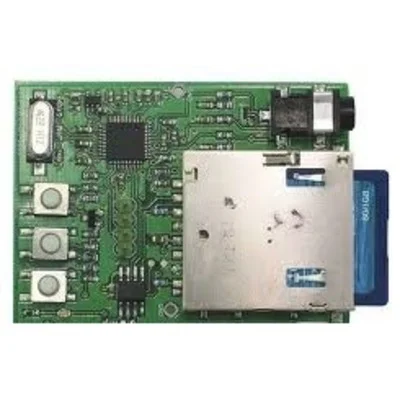
Embedded systems require high level of security and authentication in terms of software that runs on the system . Secure Boot is term normally used in systems where at boot time software modules are verified for authenticity before being launched.This is achieved by adding cryptic signature over each software module image and being verified before executing.
Points :
 PROJECT / 15
N.X.P. Semiconductors(2009-2010)
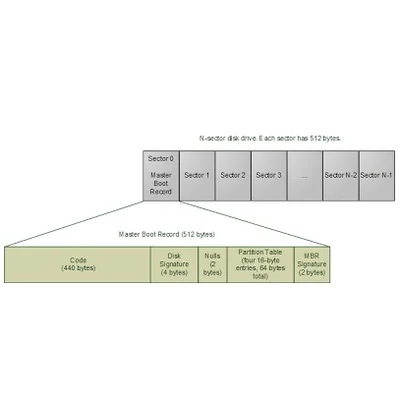
Embedded Systems these days rely on Nand Flash as main storage medium due to its small size , high I/O speed and low power consumption .Nand Flash is mostly available in SLC and MLC configuration where SLC offers more stable operations and MLC data density and cheaper cost.
In our Embedded system we decided to move from SLC Nand Flash to MLC Flash based SD card as main storage. This shift required low level software modification including linux kernel, drivers support and user-space modification.
My responsibilties were, but not limited to:
 PROJECT / 16
Research(2008-2009).
The Embedded system was designed to operate with Nand Flash but when requirement came to shift the system to SD card Interface as the main Storage medium, Pre-Study work and prototyping was required.
Important points :
My contribution:
 PROJECT / 17
Research(2009-2010)
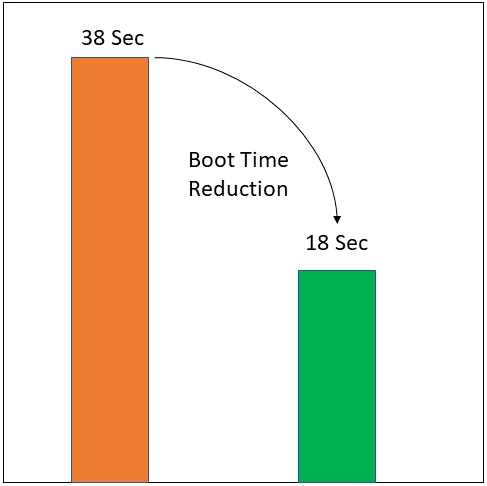
Fast Boot in Embedded systems is essential for consumer devices in Mobile, automotive and entertainment markets.
This project "System level" optimization was started with a view of reducing the Boot-Up of current by 50% by optimizing the system boot structure.
Project components :
 PROJECT / 18
N.X.P. Semiconductors(2008-2009)
Embedded Systems are shifting towards Linux as the main Operating System due to Free and Open Source distribution . Linux supports large variety architectures and flexible enough to be used from Micro-processor based systems to Servers. Linux can support variety of hardware devices and configurations thus require drivers support to be added for accessing new hardware devices.
My project responsibilities were:
 PROJECT / 19
College Project
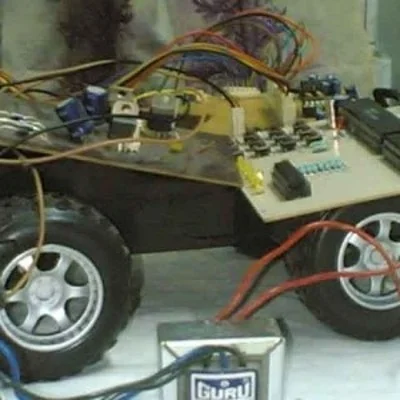
This Robotic project idea was conceived in my B.Tech college 3rd year, 2006. We created a Speech controlled robot, which would detect user speech patters, recognize them with pre-trained data and generate appropriate action. This used silicon based voice recognition chip ( HM2007 ) interfaced with 8051 micro-controller.
My role in project :
How the System worked :
The robots, sensors, processors, and embedded hardware used across the work.
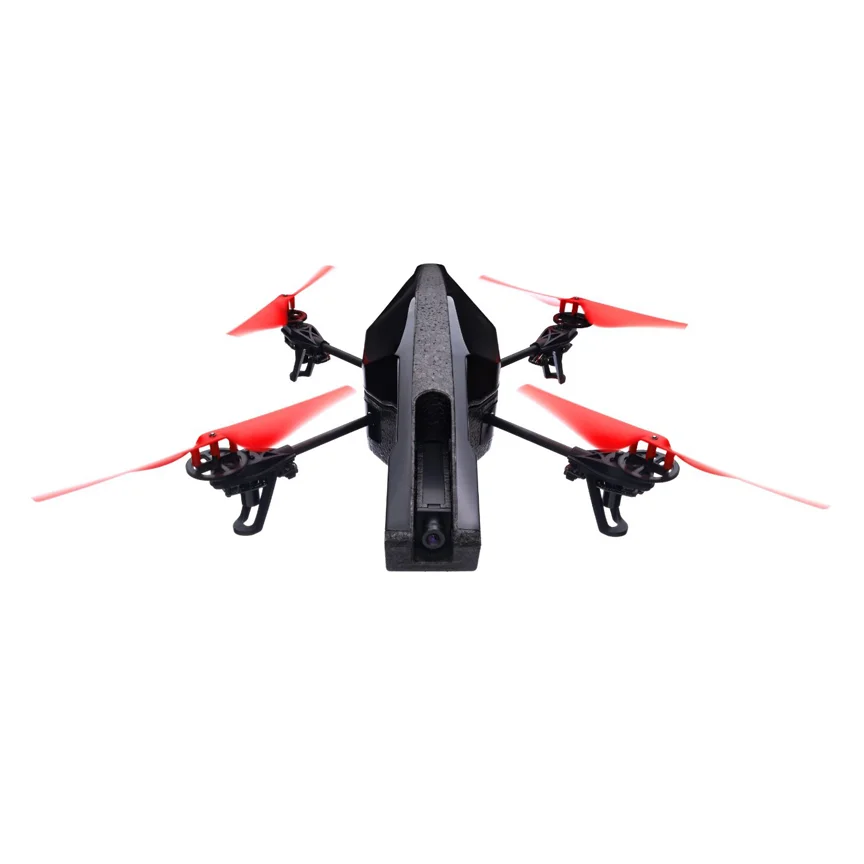
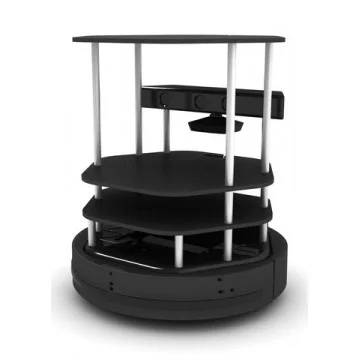
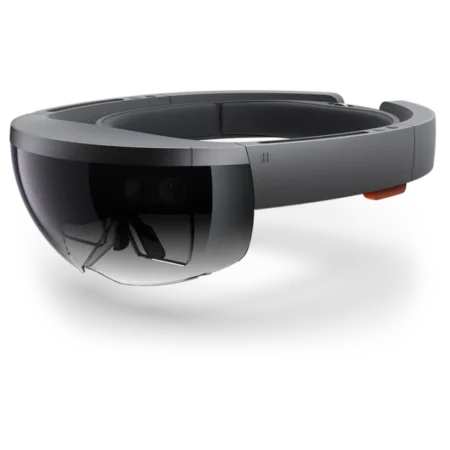
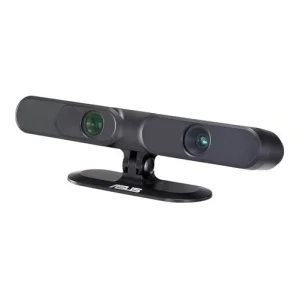
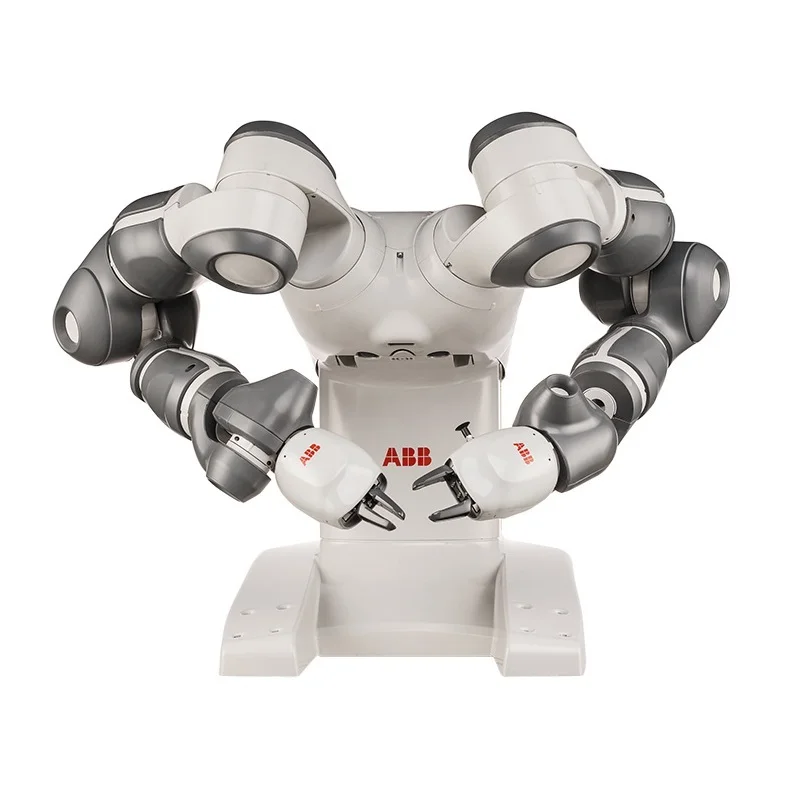
Robot and drone demonstrations.
International Institute of Information Technology, Hyderabad
9.67 / 10.0 CGPABharatiya Vidyapeeth College of Engineering, Delhi
First Class with Distinction
Senior Software Engineer(ABB)
Ordinary colleagues come and go but when a special colleague comes by, you just know. I consider myself very fortunate for having a chance to work with an expert of your caliber. Working with you was a great learning experience for me. I really value the knowledge and insight you have.
Master at RRC Lab, IIIT
Vishakh Duggal is one of the few people I know who is proficient in both robotics related software and hardware. His research focuses on practical robotic solutions for existing problems like precision agriculture and autonomous driving. His experience in product development during his industrial career has frequently placed him in an ideal position to judge next-generation technology and work accordingly. Something shown in his publication record. This expert insight is backed by a routinely updated skill set covering the state-of-the-art in optimization, machine learning, control theory, software design and modern computer architecture. Such a level of skill in both the theoretical and practical comes only with sustained dedicated effort and a passion for his field.
Tech Specialist(ABB Robotics)
I have known Vishakh since summer of 2013. We both have shared many common advance level course projects during our graduation days. His curiousity and his affinity towards learning makes him stand apart. We both have collabrated over many research projects some of which have eventually turned into publications in prestigious conferences. Throughout my association with Vishakh, I found him extremely hard working and diligent. He is a patient listener and an innovative thinker in the group.
Associate Professor at RRC Lab, IIIT
Vishakh Duggal hit the road running as he immediately set out to work on trajectory planning and optimization for quadrotors as soon as he joined us. Ever since his pace and perseverance has only increased as he tackled difficult and complex research problems with aplomb. He is a rare blend of an extremely skilled, creative and meticulous person and certainly the cynosure of all competitive organisations/companies out there
UG Researcher at RRC Lab, IIIT
I have known Mr. Vishakh Duggal since my Sophomore year as an Undergraduate Student Researcher at IIIT Hyderabad. He has been an outstanding source of inspiration to me. Not only has he motivated me to pursue Research with much vigor, but he also made me understand the importance of being self-driven. He is what I would call an "Opportunity Creator". He opened channels of collaboration with Hiroshima University and IIIT Hyderabad as an attempt to bridge the gap between two fields of research and creating exciting cross-domain research options for the upcoming Researchers at RRC (Robotics Reseach Centre). Not many people in India, being Computer Science Graduates explore the world of Electronics, much less likely, Robotics. Every move he has made in his career has had a purpose of acquiring knowledge - This sets him apart from any person I have known. Apart from being a great mentor, he has been a warm friend. The long chats we had about Robotics all over the world and life in general will always be remembered. I wish him well on his journeys further.
Robotics, research, or an interesting engineering challenge.